Robotic CNC machine tending
Problem
A manufacturer running a CNC machine needed to increase uptime per shift without adding a second operator, but manual load and unload tied the machine's cycle time directly to when an operator was free to run it.
Approach
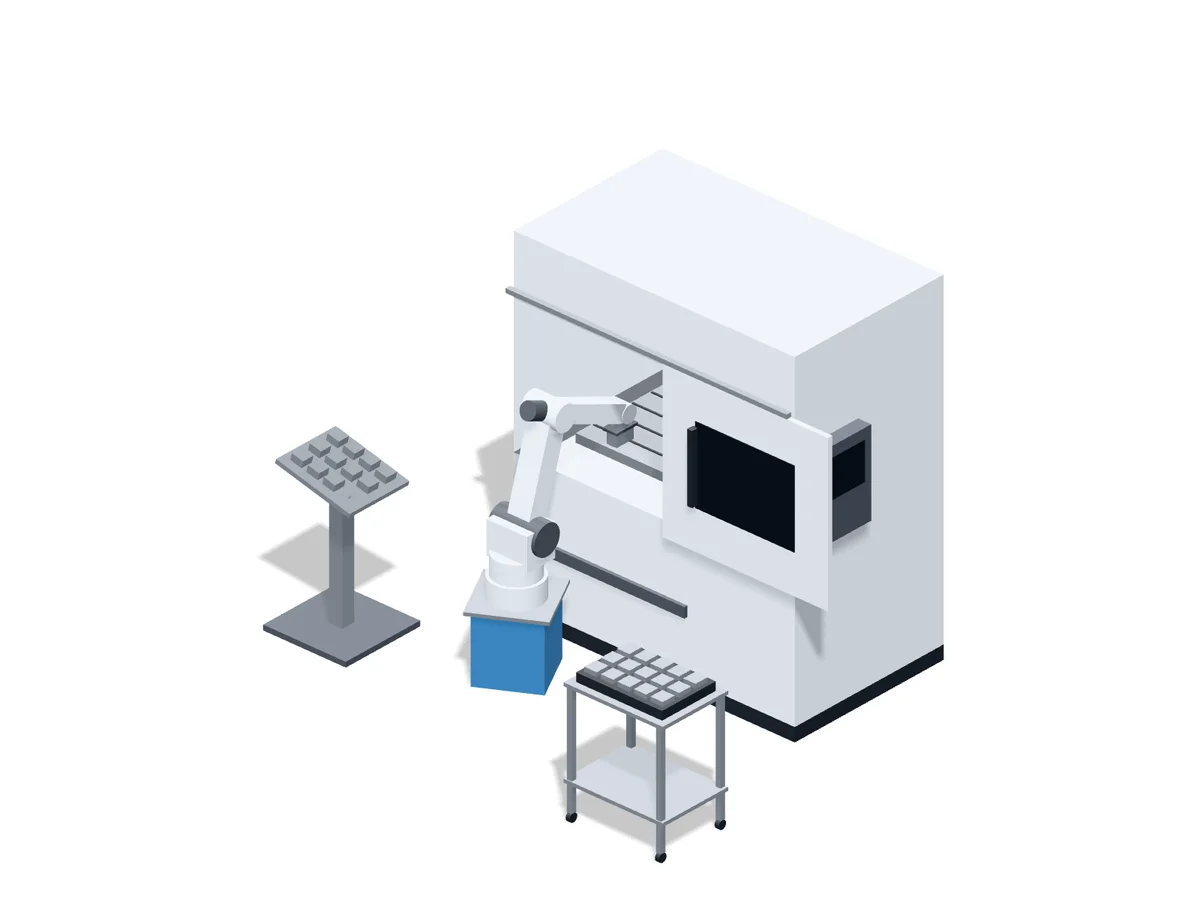
We specified and integrated a collaborative robot cell (a pedestal-mounted robot arm, a CNC controller interface, a free-standing part presenter, and end-of-arm tooling sized to the shop's part mix) around the existing CNC machine. At shift start, the operator loads a tray of raw parts and starts the cycle; the robot then works autonomously, picking, fixturing, and unloading each part through the full CNC cycle while the operator deburrs and inspects the previous tray in parallel. Any tray started before shift end runs unattended to completion. We delivered the full engineering package (electrical, pneumatic, networking, layout, and bill of materials), ran factory acceptance testing, handled on-site installation and commissioning, and trained operators and maintenance staff on the system.
Outcome
The CNC machine now runs unattended through tray changeovers and past shift end on any tray already running, giving higher uptime per shift, consistent throughput, and freeing the operator to tend a second machine at the same time.